We've started building an operating system for ground robots
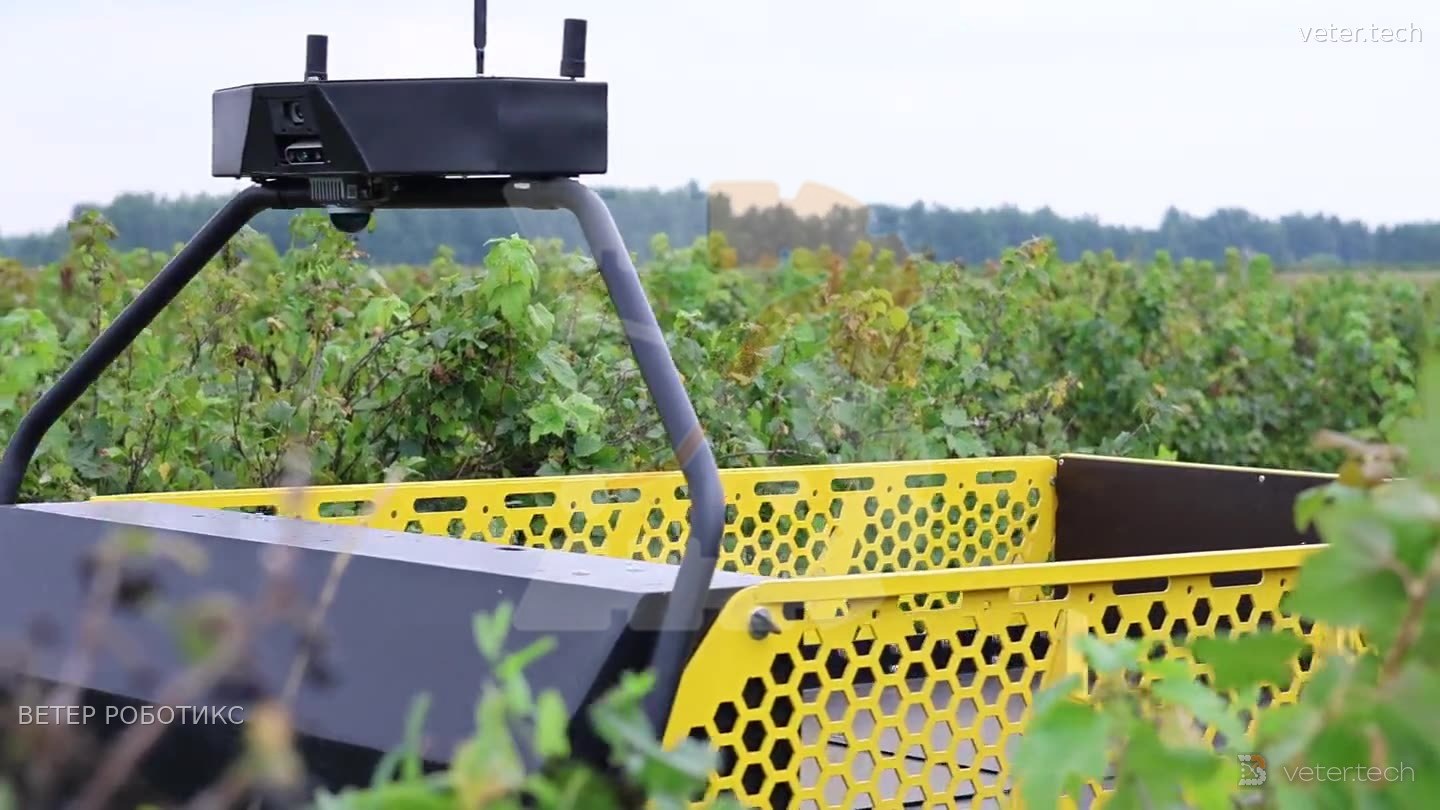
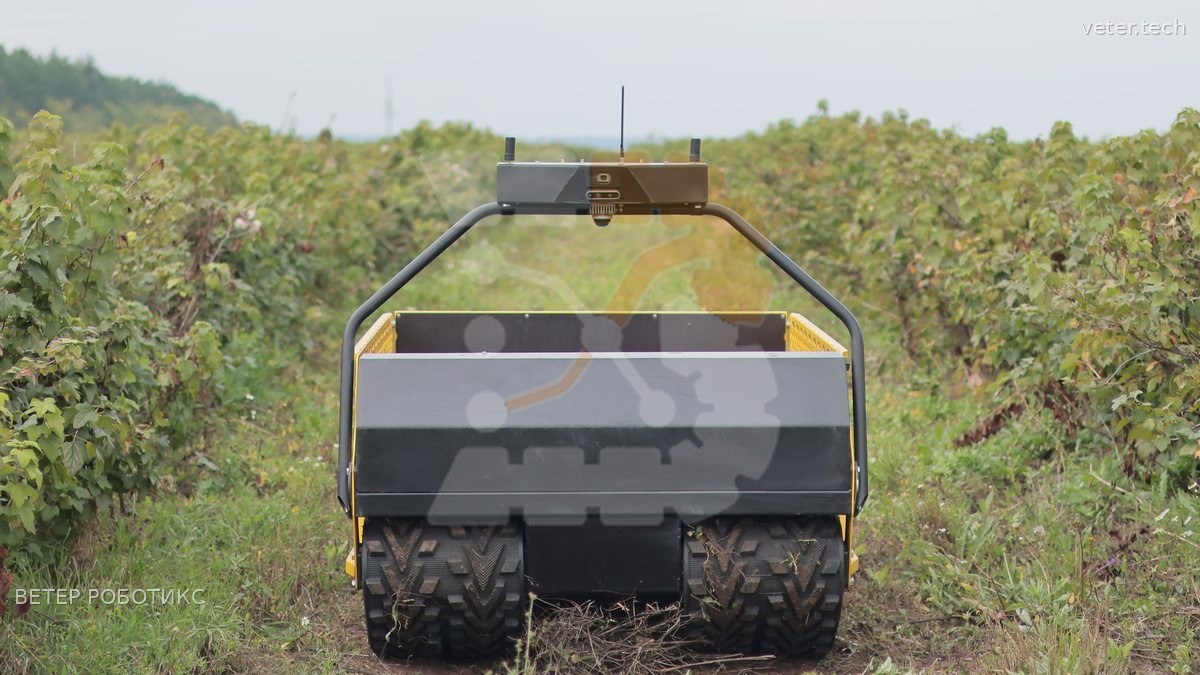
SARA OS is our own operating system for ground robots. It controls the drives, interprets the surroundings, and handles autonomy and the link to the operator's tablet.
Find us on MAX and Telegram: development and field trials, as they happen (in Russian).
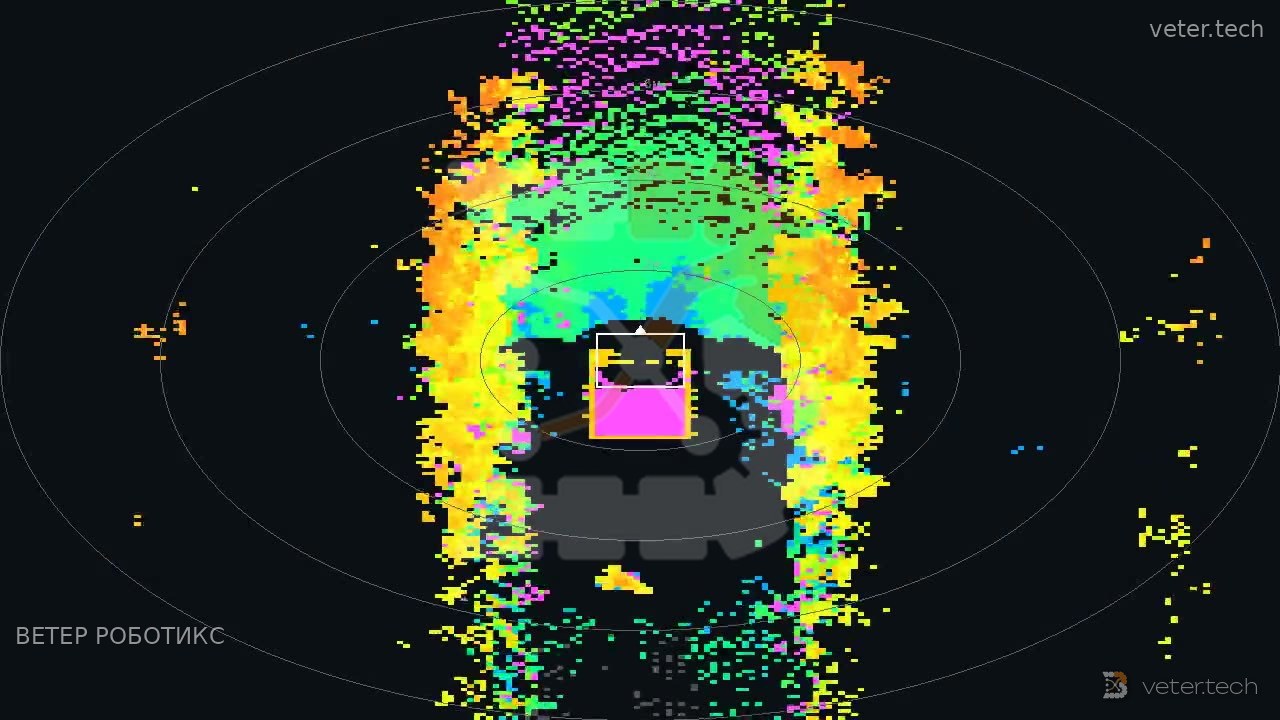
Experience, the son of hard mistakes A robot moves through an orchard slower than a person walks, and its navigation suddenly reports that it's racing along at 180 km/h. That's how the onboard DLIO localization system behaved on the VETER TEGU. A localization system calculates the machine's position from sensor data. DLIO works as a satellite-free onboard navigation system: the lidar scans the surroundings with a laser, a motion sensor picks up turns and jolts, and the software compares each new scan with the previous one to work out how far the robot has moved. If that comparison goes wrong even once, the error carries forward. FAST-LIO2 solves the same problem with the same set of sensors. What the machine saw. In the field recordings, with DLIO running live, the speed it reported would jump after a few minutes of driving - from a slow crawl to noticeably faster in a single step - and then within a few seconds climb to 180 km/h. The position drifted along with this imaginary speed, and the recorded route ballooned into tens of kilometers. How the cause was found. VETER ROBOTICS engineers replayed the same field-day recording on the onboard hardware through a different system, FAST-LIO2. The route measured by RTK satellite positioning was 332.4 m. FAST-LIO2 disagreed with it by only a few percent, while DLIO came up with 20,653 m. Same input data, different result. So the cause had to be in the position calculation itself. A caveat: this was a replayed recording. FAST-LIO2 was not driving the machine. These tests took place back in May. DLIO is only one of the localization loops in VETER ROBOTICS robots, and this analysis concerns it alone. At VETER ROBOTICS the systems are constantly being improved, and every update is run on test benches first.
You would think a ground robot's worst enemies are stairs, mud and a dead battery. In practice, what stops an inspection machine at an industrial site most often is an ordinary closed door. That story and the rest of the week's news - in our roundup of the ground robotics industry. According to The Robot Report, ANYbotics, together with dormakaba and LEGIC, has taught the four-legged ANYmal robot to pass through doors that open only with an electronic access badge. Doors like these stand at power plants, in chemical plants and at mines - you don't get in without a badge. Now the robot gets access like an employee: the door opens for it under the same rules and with the same entry in the log, and the building needs no modifications. The solution was tested at an operating facility, and it can now be added to any ANYmal machine already in service. The point is simple: an equipment inspection round only counts if the machine reaches every unit, and a closed door was the final barrier. The second story comes from the labs. Tech Xplore Robotics writes that engineers at UCLA and the University of Michigan have built an experimental frog-like robot on elastic rods that bend and twist. Across six different types of terrain, this design proved faster than traditional rigid legs. Farm use is still a long way off - this is locomotion research. But the direction is intriguing: softness instead of rigidity could come in handy where rigid legs slip, for example on loose, uneven ground. The week's third topic is reliability. The Robot Report is announcing a panel discussion by engineers from WiBotic, Burro and Nextpower at an industry conference: they will dig into why outdoor robots break down. The causes are familiar to anyone who runs equipment: temperature swings, water, dust-clogged connectors, vibration. A machine that drives beautifully around a lab fails in completely different ways outdoors. And fourth - tools for developers. On the ROS Discourse forum, where robot builders talk shop, Mission Canvas was presented: a program in which a machine's individual skills are assembled into a coherent route - where to go, what to do there and where to head next. It's a tool for the people who configure robots; a machine's owner doesn't need it directly, but it's tools like these that will one day let a robot do all this on its own. Where does VETER ROBOTICS fit in? The VETER TEGU tracked platform hauls the raspberry harvest along the rows of a berry farm - the same hauling along a known route that foreign field machines do. And the VETER SCINK tracked platform with a snow blower attachment works as a snow removal robot: it clears snow on roads and walkways.
You would think the faster a machine goes, the more energy it burns per kilometer. A test on the VETER TEGU tracked platform showed that's almost true, but the difference is smaller than you'd expect: at a steady pace from 1.4 to 3.3 km/h, consumption per kilometer rises with speed by about 10%, and above 4 km/h we have no data yet - that measurement is still to come. A turn at the end of the row, on the other hand, costs about four times as much as driving straight. The tracked chassis carries an onboard data logger - a device that automatically records current and speed while the machine works. It logged 4 days of a ground robot working in an orchard: about 3.6 hours of driving, unloaded, on gentle orchard slopes of up to 5 degrees. Only the motor current went into the measurement. The onboard electronics aren't included, even though they run all the time, even when parked, and draw an estimated 39 W - roughly like a small light bulb. So the real battery drain is slightly higher than the figures below - by that same light bulb. Most of the work happened driving straight at about 2.3 km/h - slower than a person's normal walking pace. Two things are worth distinguishing here: power is how much energy the motors are pulling right now, while consumption is how much will be spent per kilometer of travel. Driving straight at about 2.3 km/h, consumption is 1.9 Ah per kilometer. At a steady pace on level ground, consumption per kilometer rises with speed: 1.8 Ah per kilometer at 1.4 km/h and 2.0 Ah per kilometer at 3.3 km/h - a difference of about 10%. Above 4 km/h we have almost no data, so there are no conclusions yet - that measurement is still to come. What this means for a farm: the robot's speed determines how fast the battery drains over time, while consumption per kilometer of row barely changes. Covering the same row at 3.3 km/h instead of 1.4 km/h means spending about 10% more per kilometer, but in noticeably less time. A turn is a different story. The machine turns slowly, at about 1.6 km/h, but the motors pull noticeably more than they do driving straight. If you convert a turn into a kilometer of that kind of movement, you get 7.8 Ah per kilometer at about 1.6 km/h - roughly four times a kilometer of straight driving. The conclusion VETER ROBOTICS engineers give orchard owners is simple: the longer the rows and the fewer turns on the route, the farther the machine will go on a single charge. One nice detail to finish with: when the machine stands still, motor current is zero and measured power is 0 W - only the electronics are running, with their calculated 39 W. A pause in the work costs almost nothing. And over all 4 days the motors never heated above 41 degrees - warmer than a human hand, but a long way from overheating.

 MAX
 Telegram